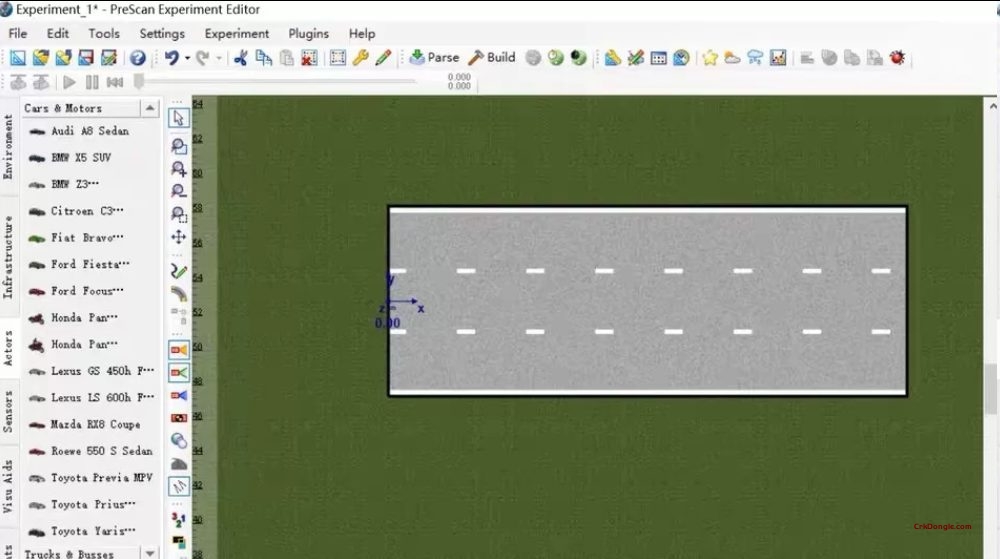
Simcenter Prescan 2606: AI-Driven ADAS & Autonomous Driving Simulation Platform
Simcenter Prescan 2606 is the latest release of Siemens’ ADAS and autonomous driving simulation platform, published in July 2026. This version centers on Python-native simulation and AI-assisted workflows, embedding simulation capability directly into modern software development environments while delivering significant gains in large-scale scene rendering and physics-based sensor performance.
Key New Features
Python-Native Simulation Workflow
Version 2606 brings simulation directly into the Python development ecosystem. Engineers can run complete simulations in VS Code, PyCharm, and similar environments, programmatically control scenario logic and actuators, and read camera/lidar/radar sensor data in real time. The Python API ships with type information for autocompletion, and AI coding assistants can understand the Prescan API through SKILL files to help generate scenario code.
OpenSCENARIO Standard Workflow Enhancements
Adds support for OpenSCENARIO 1.2 and 1.3, improving import and reusability of dynamic scenarios and increasing automation in scenario construction.
Physics-Based Sensor Performance Improvements
-
Physics-based Lidar (PCL): Adds Multi-GPU support, distributing a single sensor’s computational load across multiple GPUs for optimal performance with modern GPU architectures
-
Radar Scene Simulator (RSS): Adds sensor detection data output, providing transmit angles of multi-beam rays plus first and last path lengths, enabling custom signal processing modules and multipath reflection studies
Large-Scale Scene Rendering Acceleration
-
Geometry Instancing: Efficiently renders thousands of repeated objects (vegetation, roadside elements) with low memory footprint and GPU acceleration
-
SceneNode Referencing: Reuses complex assets (trees, vehicles) by referencing Scene files, supporting large-scale scene composition